LiDAR vs radar comes down to light against radio waves. LiDAR fires laser pulses and builds a detailed 3D map of its surroundings, accurate to a few centimeters. Radar sends radio waves that see less detail but reach farther, measure speed directly and keep working in fog, rain and dust.
That trade-off explains why most robots and self-driving cars carry both. Below you'll find a side-by-side table, where each sensor fails, how 4D imaging radar and FMCW LiDAR are closing the gap, the Tesla vs Waymo debate, and what the data from each sensor looks like when you train a perception model on it.
What Is the Difference Between LiDAR and Radar?
The difference between LiDAR and radar is the wavelength they use. LiDAR (light detection and ranging) uses near-infrared laser light, usually at 905 or 1550 nanometers, and returns dense 3D point clouds. Radar (radio detection and ranging) uses radio waves with wavelengths in millimeters to meters, which gives lower resolution but longer range, direct speed measurement and reliable operation in bad weather.
Everything else follows from that one physical fact. A shorter wavelength resolves smaller details, so LiDAR can tell a pedestrian's arm from their torso. A longer wavelength passes through water droplets and dust that scatter light, so radar still sees the car ahead in a downpour.
LiDAR vs Radar at a Glance
| LiDAR | Radar |
|---|
| Signal | Laser light (near-infrared) | Radio waves (microwave / millimeter wave) |
| Typical wavelength | 905 nm or 1550 nm | About 4 mm for 77 GHz automotive radar |
| Resolution | High: fine 3D shape of objects | Low to medium: position and rough size |
| Range | Usually up to about 200 to 300 m for automotive units | Up to 300 m for automotive units, hundreds of km for weather and air traffic radar |
| Speed measurement | Indirect (compares frames), except FMCW LiDAR | Direct, via the Doppler effect |
| Fog, rain, dust, snow | Performance drops sharply | Works reliably |
| Darkness | Works (own light source) | Works |
| Cost | Higher, though falling fast | Lower, mass-produced for cars |
| Output data | 3D point cloud (x, y, z, intensity) | Sparse detections with range, angle and velocity |
| Typical uses | Mapping, surveying, robotics, autonomous driving | Adaptive cruise control, aviation, maritime, weather, speed enforcement |
How LiDAR Works
A LiDAR unit sends out short laser pulses and times how long each one takes to bounce back. Light travels at a known speed, so the round-trip time gives the distance to whatever the pulse hit. Repeat that hundreds of thousands of times per second across a wide field of view and you get a point cloud: a 3D snapshot of the scene made of individual measured points.
Mechanical LiDARs spin to cover 360 degrees, which is the classic look of early self-driving prototypes. Solid-state designs steer the beam electronically or with tiny mirrors, so they're smaller, cheaper and easier to hide behind a windshield or bumper.
905 nm vs 1550 nm
Most automotive and robotics LiDARs run at 905 nm. Silicon detectors for that wavelength are cheap and mature. The catch is eye safety: 905 nm light can reach the retina, so output power is capped, which limits range.
1550 nm light is absorbed before it reaches the retina, so these systems can fire much stronger pulses and see farther. They need more expensive indium gallium arsenide detectors, though, and water absorbs 1550 nm light more strongly, which hurts in rain. Luminar is the best-known 1550 nm supplier for cars.
How Radar Works
Radar sends out radio waves and listens for the echo. The delay gives distance, the antenna array gives direction, and the frequency shift of the echo (the Doppler effect) gives the target's speed toward or away from the sensor. That last point matters a lot: radar knows how fast something moves from a single measurement, while classic LiDAR has to compare two frames to work it out.
Automotive radar bands
Modern car radars work in the 76 to 81 GHz band, which the FCC opened for vehicle radar in 2017. At 77 GHz the wavelength is about 4 mm, short enough for decent resolution and long enough to pass through rain. Long-range units watch the road far ahead for adaptive cruise control, while short-range corner radars cover blind spots and cross traffic.
Radar also comes in forms that build images rather than just detecting objects. Synthetic aperture radar (SAR), carried on satellites and aircraft, uses the platform's motion to create high-resolution images of the ground day or night through cloud cover. We cover how teams train models on it in our guide to synthetic SAR data for computer vision training.
Where Each Sensor Fails
Neither sensor is better across the board. Each has blind spots that the other one covers, which is the whole argument for using both.
LiDAR: weather and tricky surfaces
Fog, heavy rain, snow and dust scatter laser light, so LiDAR range and point density drop fast when visibility does. Falling snowflakes and road spray also show up as false points that a perception model has to filter out. Very dark surfaces, such as black car paint, absorb much of the laser and return weak signals, while mirrors and wet roads can reflect the beam away entirely.
Radar: low resolution and clutter
Radar sees objects as a handful of reflections, not as shapes. It struggles to tell a pedestrian standing next to a parked car from the car itself, and it can't read lane lines or signs. Metal objects like manhole covers, guardrails and overhead signs reflect strongly and create clutter, which is one reason older radar systems ignored stationary objects to avoid phantom braking.
4D Imaging Radar and FMCW LiDAR: The Gap Is Closing
The neat split between "precise LiDAR" and "weatherproof radar" is getting blurrier, and two technologies are behind it.
4D imaging radar adds elevation to the usual range, azimuth and velocity, and uses many more antenna channels to raise resolution. The output starts to look like a sparse point cloud instead of a few blips. It can tell an overhead bridge from a stopped truck under it, which classic automotive radar often couldn't.
FMCW LiDAR (frequency-modulated continuous wave) works more like radar: instead of timing pulses, it sweeps the frequency of a continuous laser beam and reads the shift in the return. That gives every point a direct velocity measurement, plus better resistance to sunlight and interference from other LiDARs. Aeva and Aurora are two companies building FMCW systems.
Neither one replaces the other yet. Imaging radar still can't match LiDAR's fine geometry, and FMCW LiDAR still suffers in fog. But both shrink the list of jobs only one sensor can do.
LiDAR vs Radar vs Camera (and Sonar)
Cameras are the third sensor in almost every perception stack, and they're the only one that sees color, texture and text. That makes them essential for traffic lights, lane markings and signs. They're also the cheapest of the three. Their weak points are depth, which they have to estimate rather than measure, and low light or glare.
Sonar, which uses sound waves, rounds out the family. Sound travels well through water and poorly through air, so sonar dominates underwater mapping and vessel navigation, while in cars it's limited to short-range parking sensors.
| Camera | LiDAR | Radar | Sonar |
|---|
| Measures depth directly | No | Yes | Yes | Yes |
| Color and text | Yes | No | No | No |
| Speed directly | No | Only FMCW | Yes | Yes |
| Bad weather | Weak | Weak | Strong | Short range only (in air) |
| Best at | Classifying what things are | Precise 3D shape and position | Range and speed in any weather | Underwater and very short range |
LiDAR vs Radar in Self-Driving Cars: Tesla vs Waymo
The two best-known approaches to autonomy sit at opposite ends of the sensor debate.
Waymo stacks sensors. Its sixth-generation driver uses 13 cameras, 4 LiDARs and 6 radars, according to Waymo's own announcement. The logic is redundancy: if rain blinds the LiDAR or glare blinds a camera, radar still tracks the traffic around the car.
Tesla went the other way. It never used LiDAR in its production cars and removed radar from the Model 3 and Model Y in 2021, moving to a camera-only system it calls Tesla Vision. Elon Musk has long called LiDAR in cars a "fool's errand", arguing that humans drive with vision alone, so a car should be able to as well. The bet is that enough training data and compute can turn cameras into a full depth sensor.
Most automakers and robotaxi companies land closer to Waymo. Driver assistance systems in mass-market cars typically combine a front camera with one or more radars, and LiDAR is showing up in more premium models as prices fall.
LiDAR vs Radar Speed Guns
Police use both, and the difference is mostly about targeting. A radar gun sends a wide cone of radio waves, so it can pick up speeding traffic from a distance or from a moving patrol car, but it can't always say which car in a group it measured. A LiDAR gun fires a narrow laser beam at one specific vehicle, so the officer knows exactly which car was clocked. The trade-off is that the officer has to aim it, usually while parked.
What the Data Looks Like for Machine Learning
For a team building perception for a robot, a drone or a vehicle, the sensor choice is also a data choice. Each sensor produces a different kind of input, and each one needs its own models, labels and training sets.
Point clouds vs radar returns
A LiDAR frame is a point cloud: often tens of thousands of points with x, y, z coordinates and an intensity value. Models such as PointPillars or CenterPoint turn it into 3D bounding boxes or per-point segmentation. Point density falls with distance, so a pedestrian 80 meters away may be just a few dozen points.
Radar output is far sparser. A conventional automotive radar might return only a few hundred detections per frame, each with range, angle, velocity and signal strength. 4D imaging radar adds elevation and density, but it's still a fraction of a LiDAR scan. Models lean on velocity and on fusing radar with camera or LiDAR data rather than reading shape from radar alone.
Why training data is the bottleneck
Labeling 3D data is slow. An annotator has to draw a box around every car, cyclist and pedestrian in 3D space, frame after frame. Radar is even harder to label by hand, because a few reflections rarely look like the object that caused them. Most teams label radar by projecting labels from synchronized LiDAR or camera data.
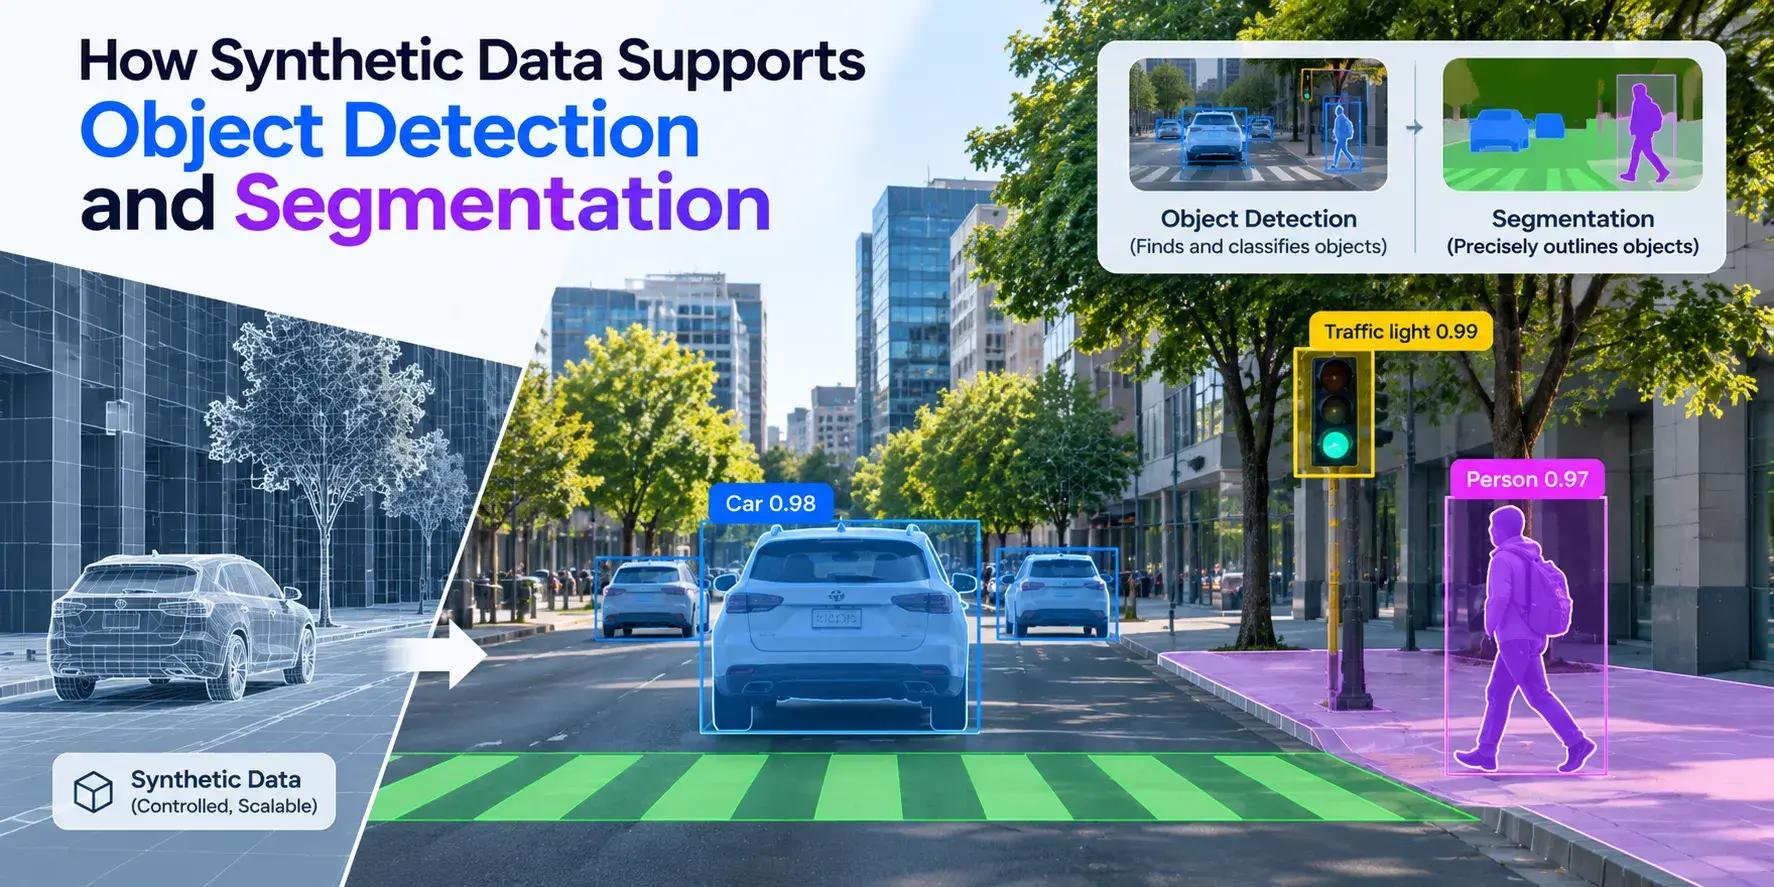
The hardest part is coverage. The cases that break perception models are rare ones: a child stepping out between parked cars in heavy rain, debris on a highway at night, a forklift half hidden behind a shelf. Collecting enough real examples of each takes years of driving or operation. That's why robotics and autonomy teams increasingly generate synthetic data for robotics training, where every object comes labeled and rare scenarios can be produced on demand. Our guide on how to generate edge cases for computer vision models walks through that process.
Sensor Fusion: How Robots and Autonomous Vehicles Combine Them
Sensor fusion merges data from cameras, LiDAR and radar into one picture of the world. There are three common ways to do it.
Early fusion combines raw data before any detection happens, for example by painting camera colors onto LiDAR points. It keeps the most information but requires precise calibration and synchronization. Late fusion runs a separate detector on each sensor and merges the resulting object lists, which is simpler and more fault-tolerant but throws away detail. Mid-level fusion, now common in research and production, merges learned features from each sensor inside one neural network, often in a bird's-eye-view representation of the scene.
The same principle applies beyond cars. Warehouse robots pair 2D LiDAR with cameras for navigation and picking. Drones combine cameras with LiDAR for mapping, a setup we cover in our article on drone computer vision. Maritime systems lean on radar for long-range vessel detection and add cameras to classify what they find.
Choosing Between LiDAR and Radar
If your system needs precise 3D geometry at short to medium range, in mostly clear conditions, LiDAR is the stronger sensor. If it needs long range, direct speed measurement or reliability in rain, fog and dust, radar wins. If people or expensive equipment are at stake, you'll almost certainly want both, plus cameras, and a perception model trained on data from all of them.
Whatever the LiDAR vs radar mix in your stack, the model behind it is only as good as its training data. Vivid 3D builds synthetic datasets for robotics and physical AI teams, from RGB images to depth and point clouds, with labeled rare scenarios that are hard to capture in the real world. Book a demo to see what that looks like for your use case.
Frequently Asked Questions
Does Tesla use radar or LiDAR?
Neither in its main approach. Tesla has never used LiDAR in production cars and removed radar from the Model 3 and Model Y in 2021. Its driver assistance relies on cameras and neural networks, a setup Tesla calls Tesla Vision.
Do cops use LiDAR or radar?
Police use both. Radar guns cover a wide area and work from a moving patrol car, while LiDAR guns use a narrow laser beam to clock one specific vehicle. LiDAR is preferred in heavy traffic, where the officer needs to prove exactly which car was speeding.
What did Elon Musk say about LiDAR?
At Tesla's 2019 Autonomy Day, Musk called LiDAR a "fool's errand" for self-driving cars and said companies relying on it were doomed. His argument is that roads are designed for human vision, so cameras plus strong AI should be enough.
What can LiDAR not penetrate?
LiDAR cannot see through solid objects, walls or dense foliage, and its performance drops sharply in fog, heavy rain, snow and dust. It can pass through gaps in tree canopy, which is why it's used to map the ground under forests, and specialized green-wavelength LiDAR can measure shallow water depth.
Is LiDAR more accurate than radar?
For position and shape, yes. LiDAR measures distance to within a few centimeters and captures fine 3D detail. Radar is more accurate for speed, which it measures directly, and more dependable in poor weather, so the better choice depends on what you need to measure.